Design
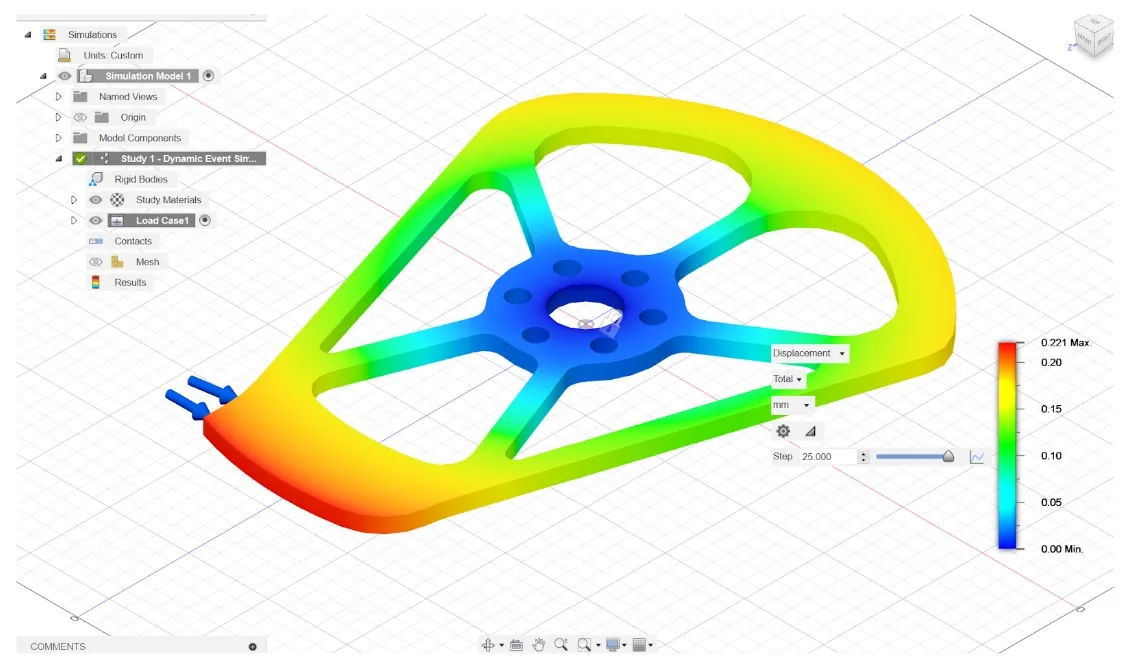
SolidWorks · Fusion 360 · Onshape · Inventor · FEA · GD&T · mechanism design · DFM/DFA
MECHANICAL ENGINEER · ROBOTICS
I build robots, break them, fix them, and then figure out how to make the next one easier to build.
PUBLIC FOOTPRINT
THE SHORT VERSION
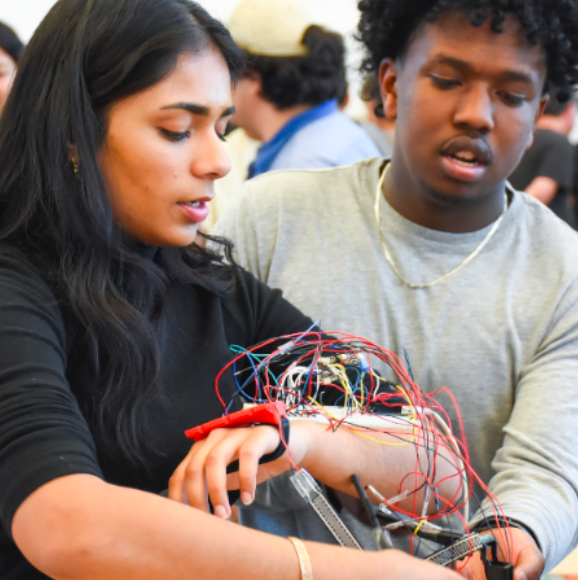
My strongest work sits at the boundaries between disciplines. I am comfortable designing mechanical hardware, making parts in a shop, wiring and debugging a robot, working with firmware and software, bringing up a new system, and figuring out how a team can build and operate it repeatedly.
I like robotics because the problems refuse to stay inside one engineering discipline.
01 · THINGS I’VE ACTUALLY BUILT
Combat robots, humanoids, manipulation, sensing, product development, and the machines I kept working on after class ended.
COMBAT ROBOTICS
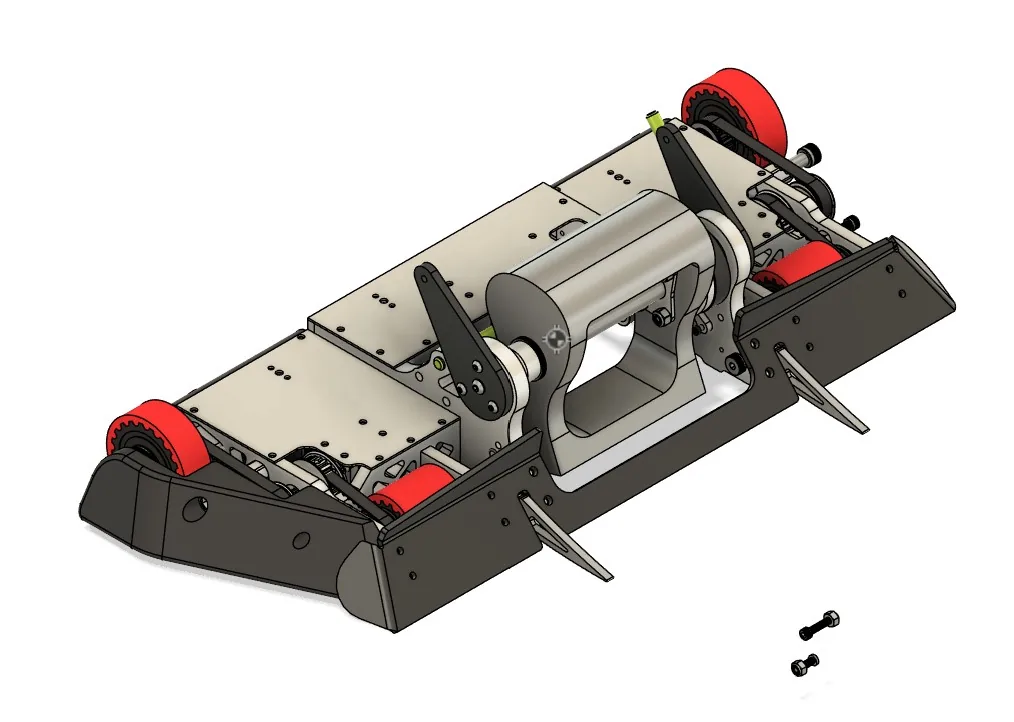
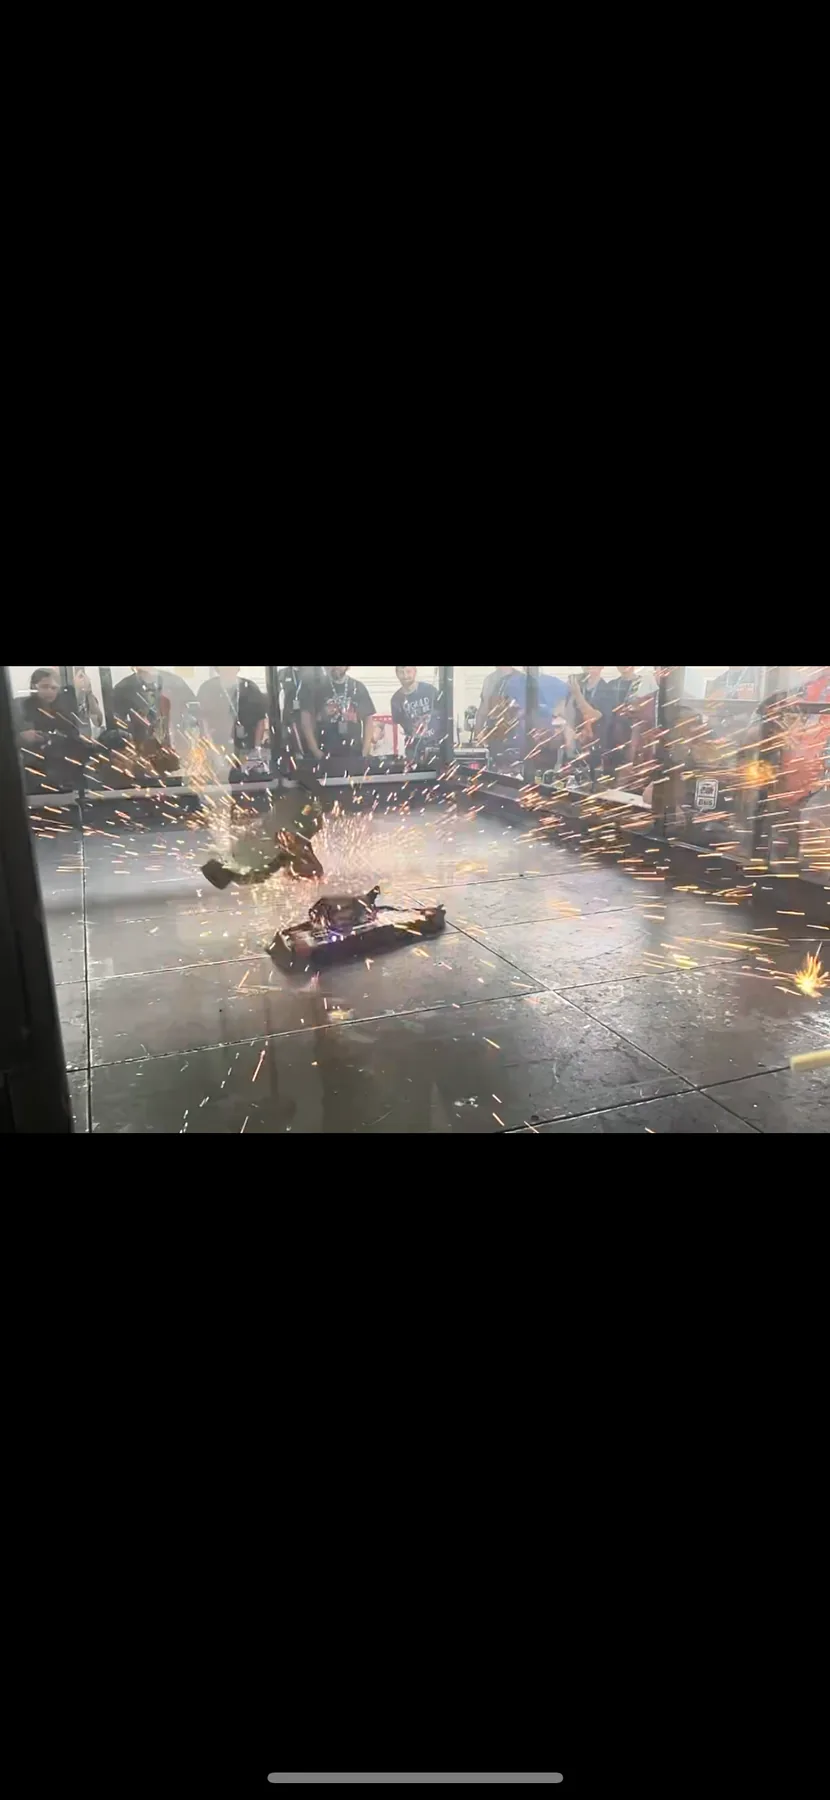
A full robot program: weapon design, machining, heat treatment, wiring, troubleshooting, people, parts, and competition driving.
OPEN PROJECT ↗
COMBAT ROBOTICS
Poundtown (15 lb) and Global Pounding (12 lb), with original build photos, manufacturing notes, and competition links.
OPEN PROJECT ↗ULTIMATE FIGHT BOTS
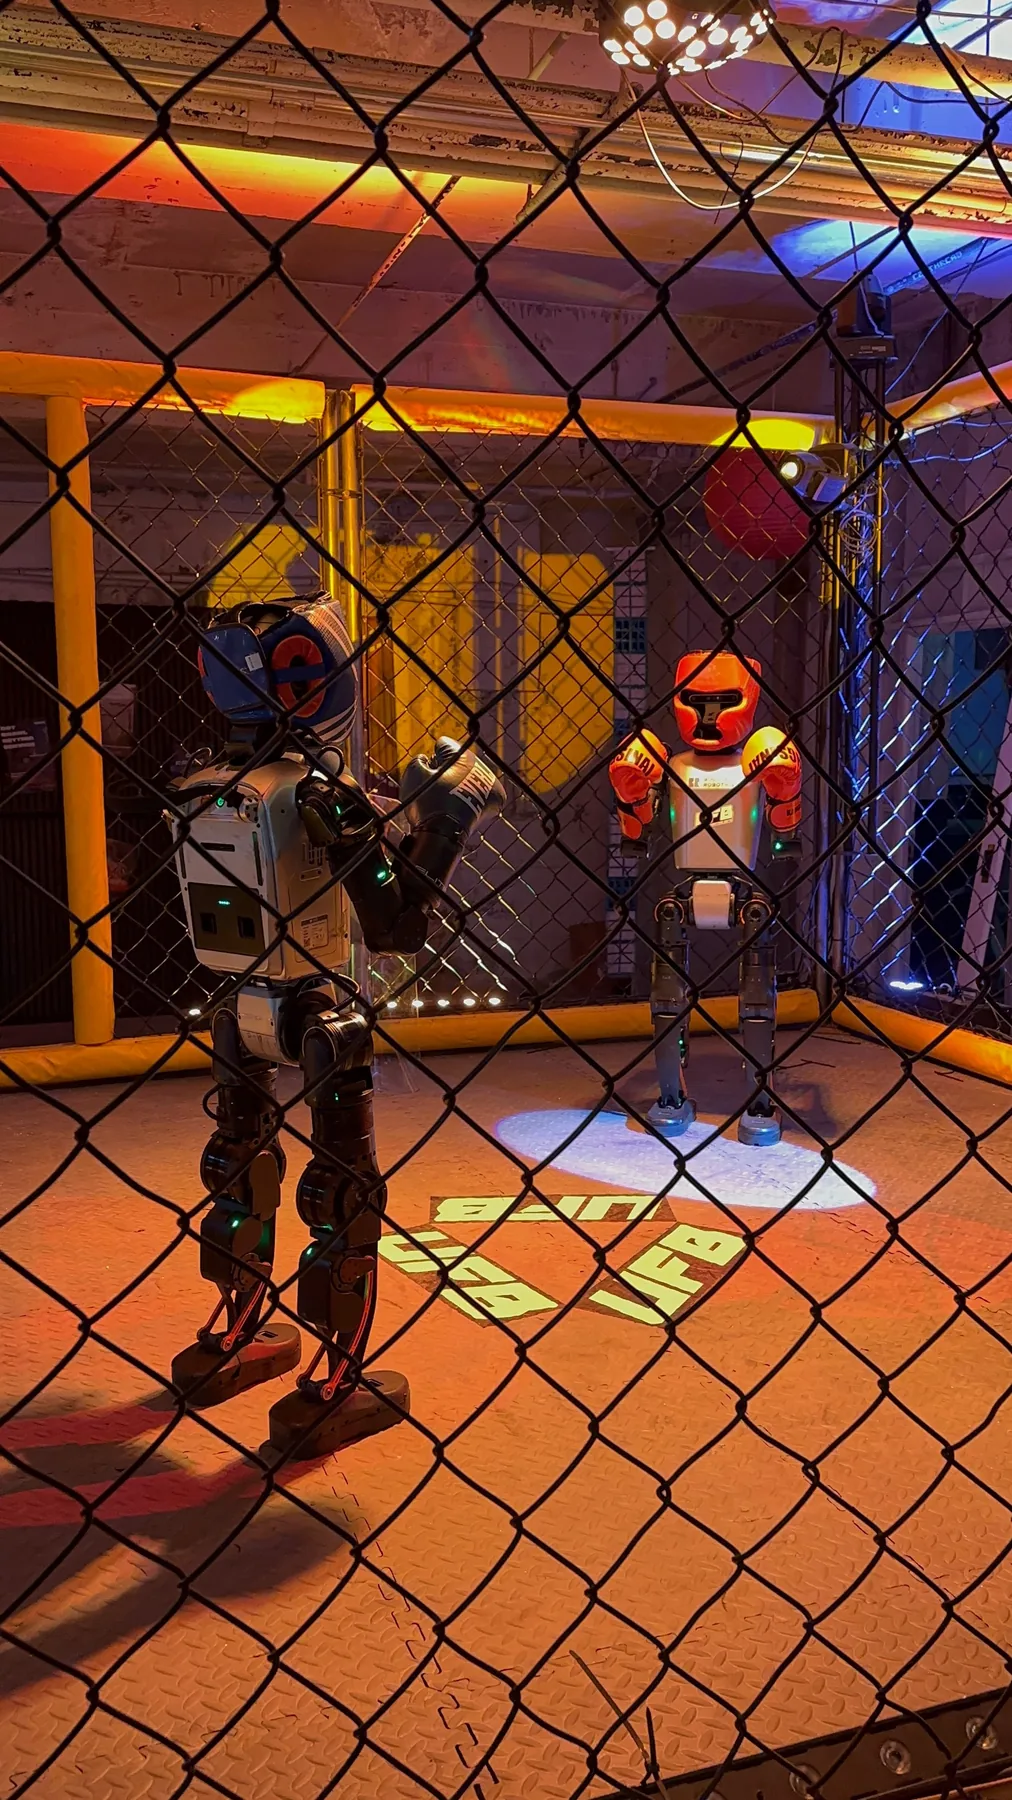
Unitree + Booster integration, calibration, motion behaviors, debugging, recovery, and live robot fights.
OPEN PROJECT ↗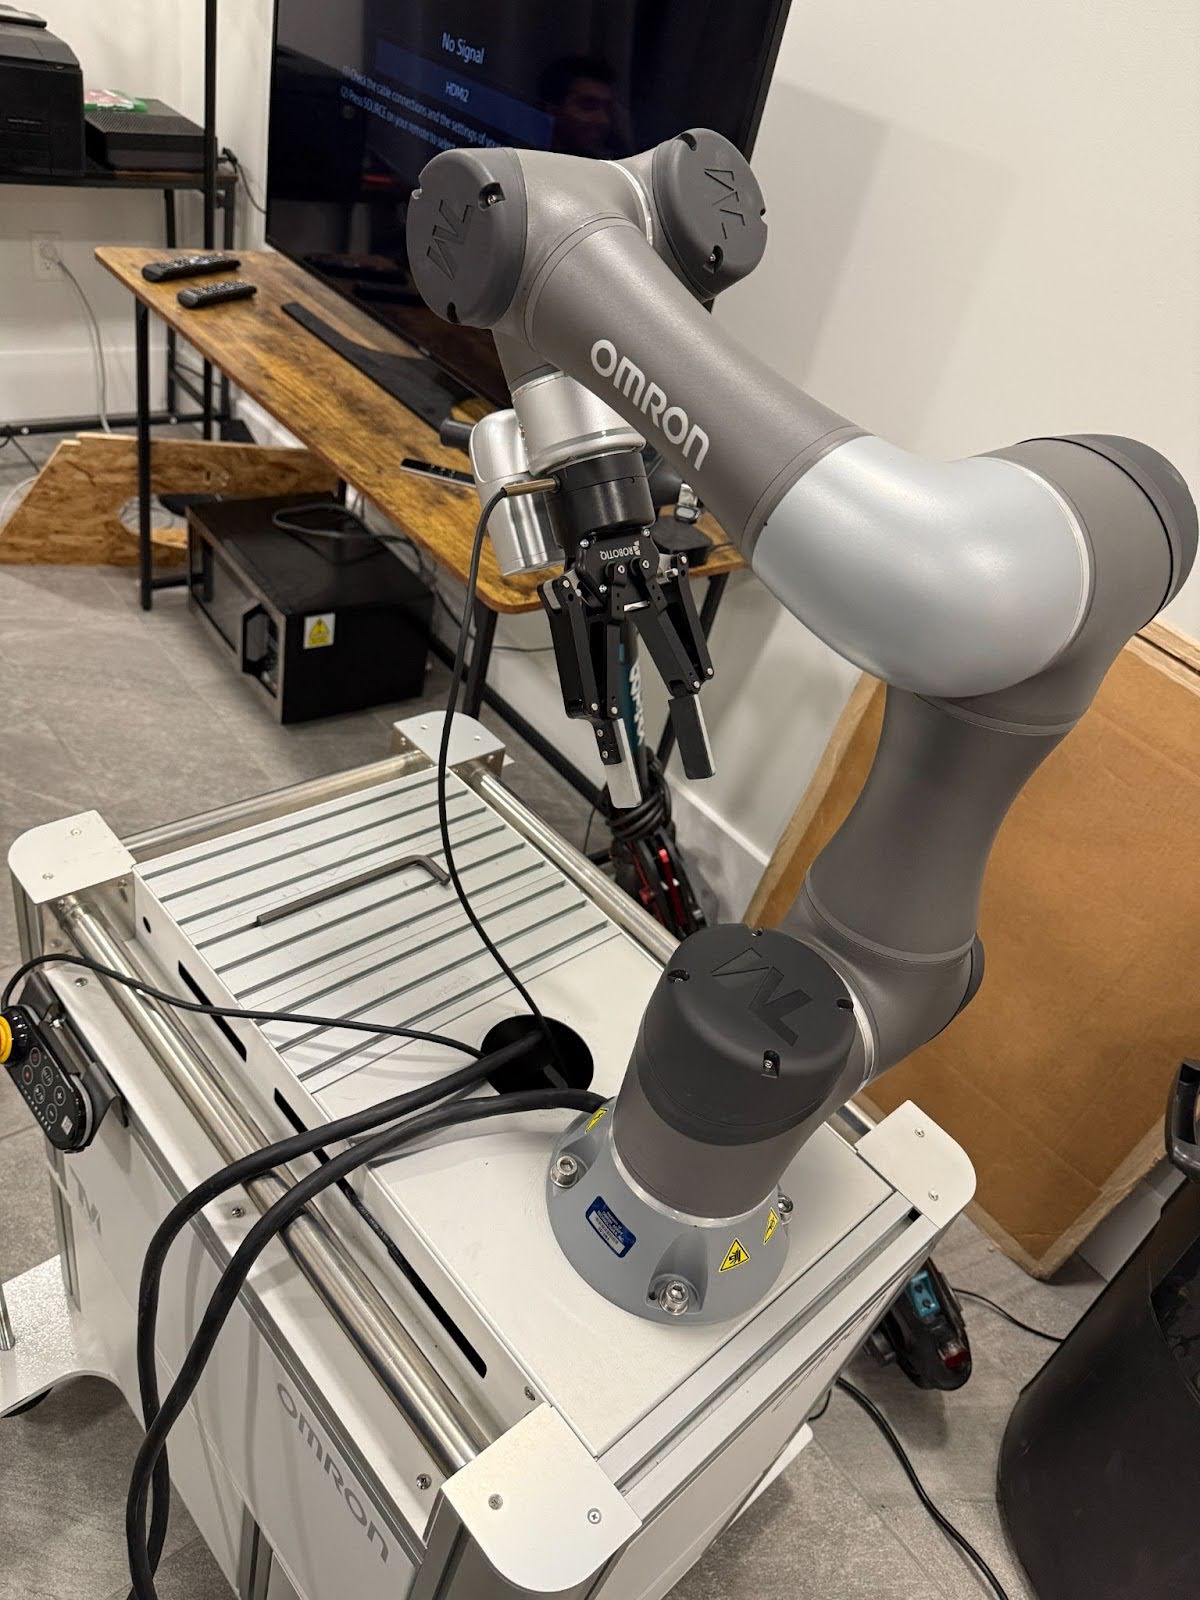
UC BERKELEY · GROCERYGIZMO
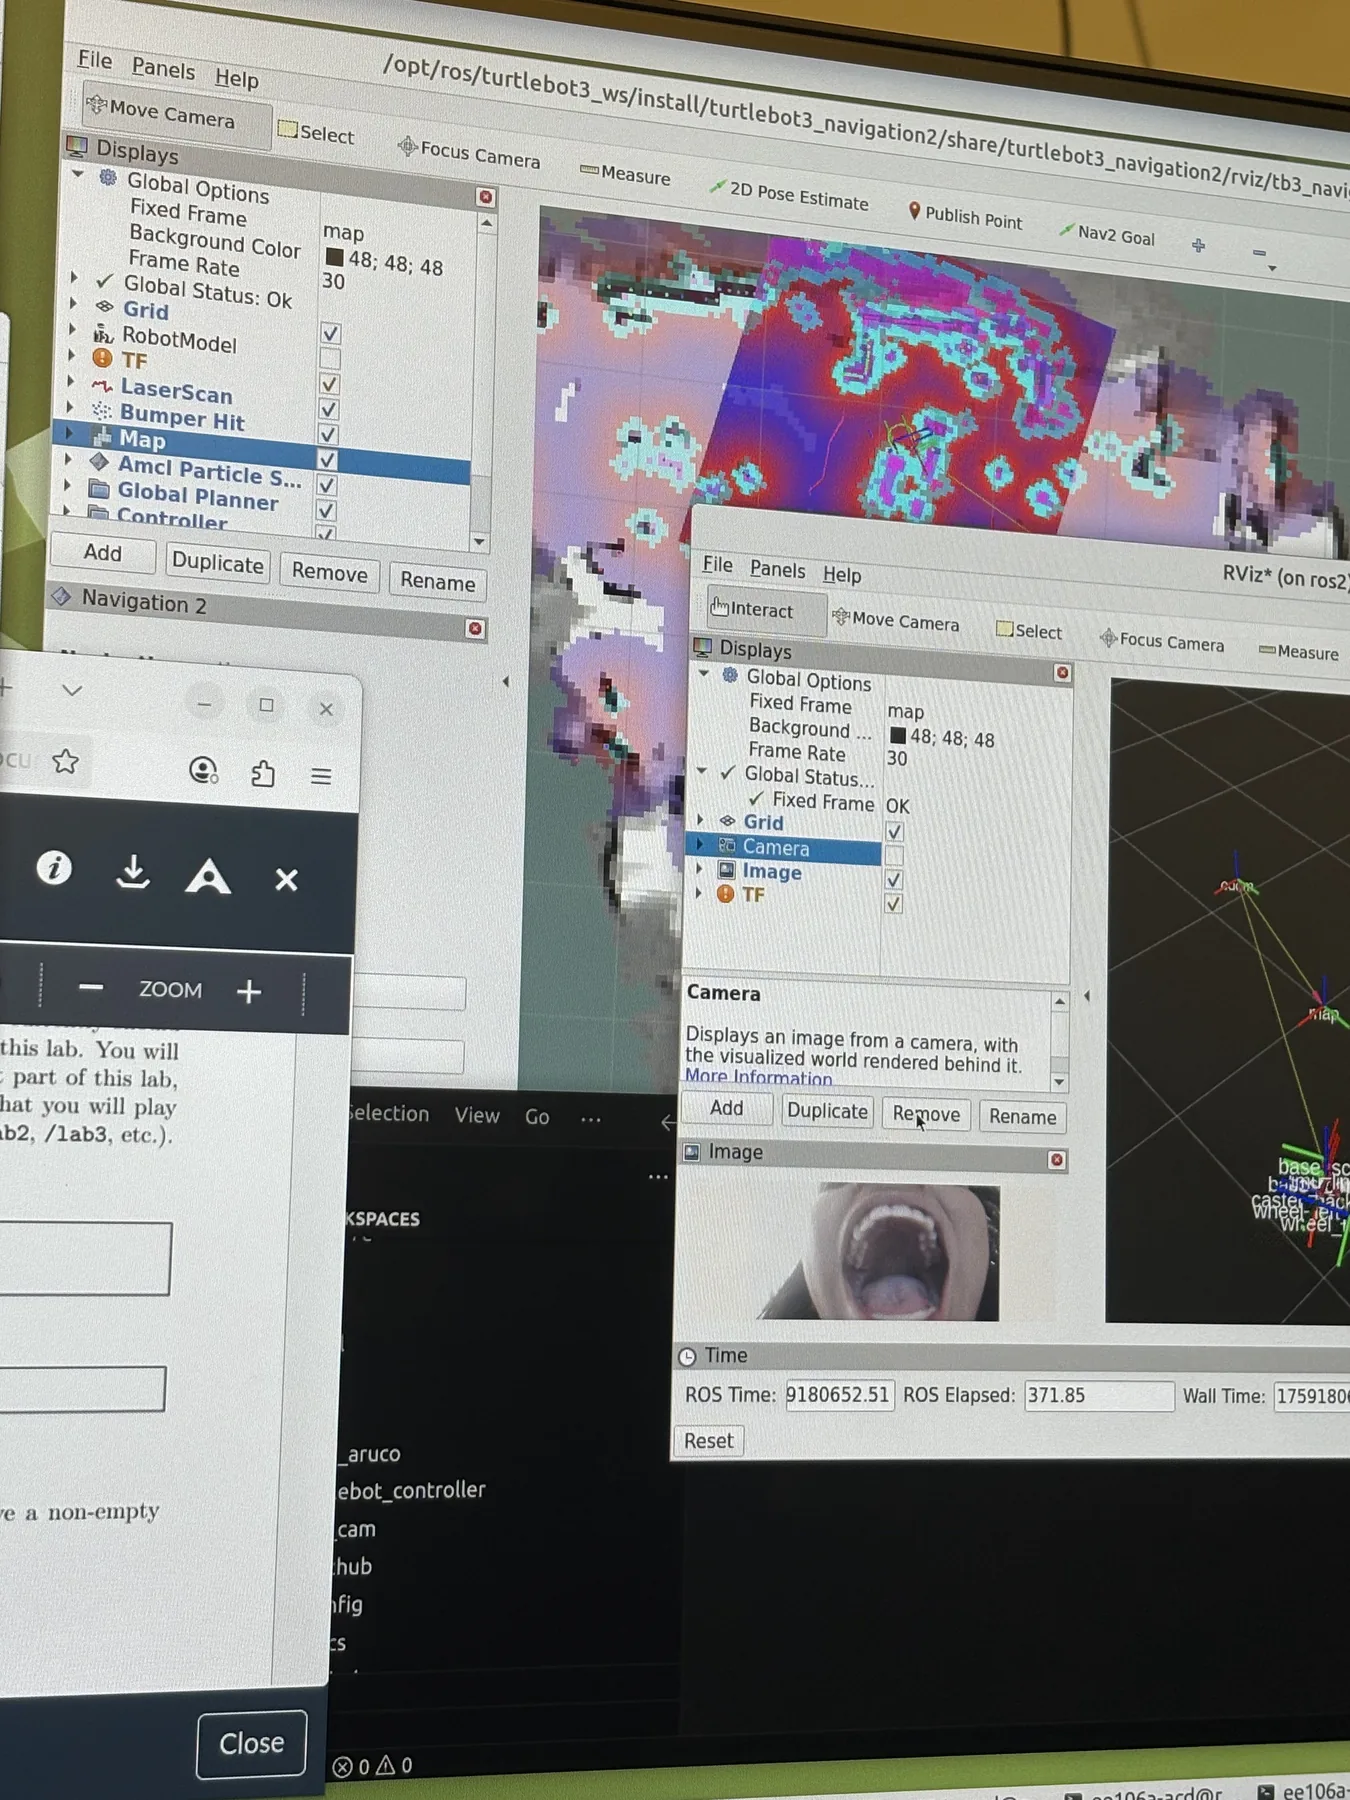
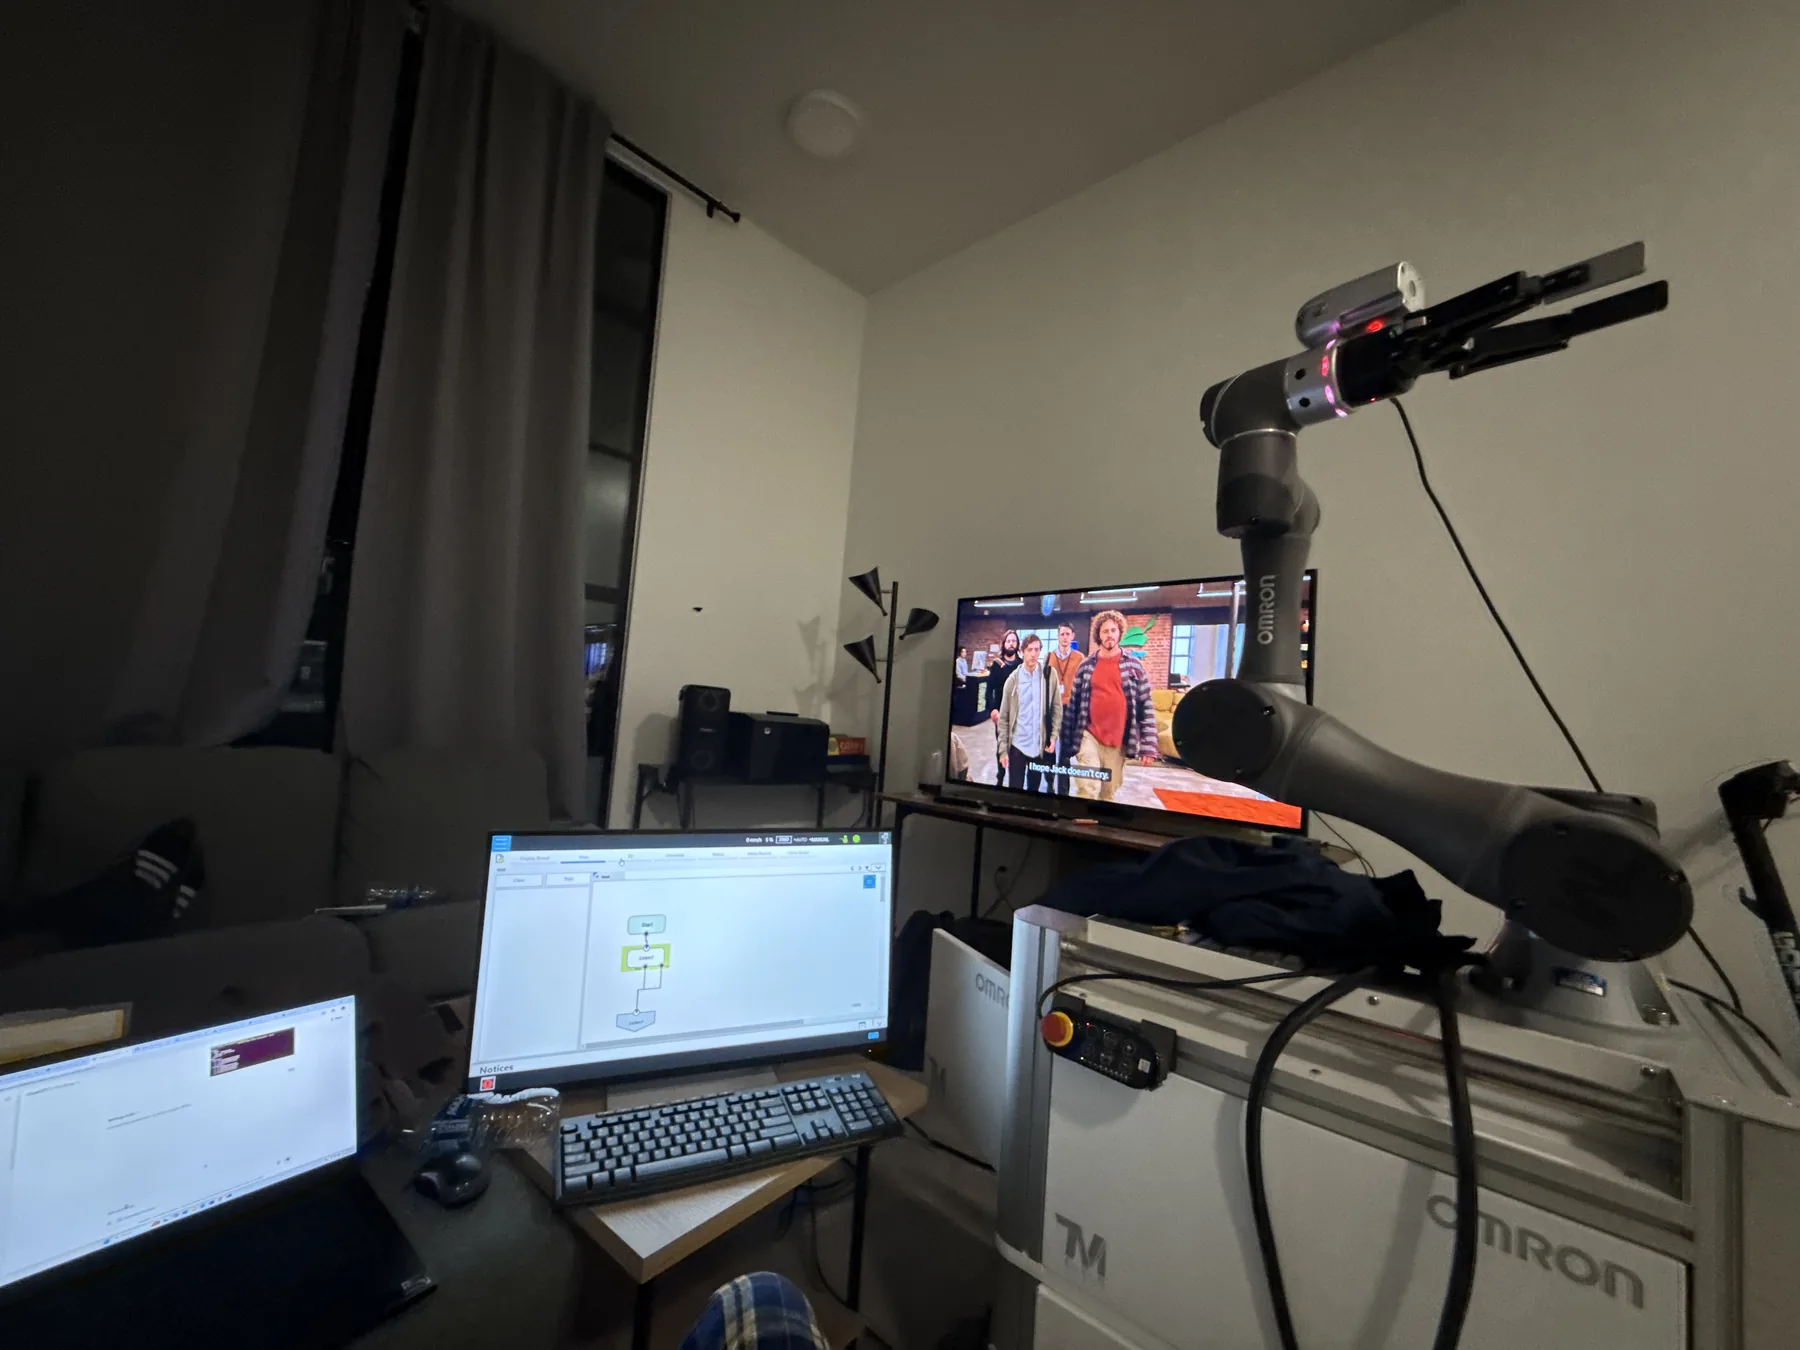
Omron TM5-700, RealSense, AR tags, ROS 2, MoveIt2, Robotiq, custom CAD, and manipulation recovery.
OPEN PROJECT ↗UC BERKELEY
Sensor component + robotic portion of a teleoperated humanoid hand, backed by the original final report and shop presentation.
OPEN PROJECT ↗ROBOTICS · MANIPULATION
Multi-DOF manipulators spanning planning, control, perception, hardware integration, and industrial-arm exposure.
OPEN PROJECT ↗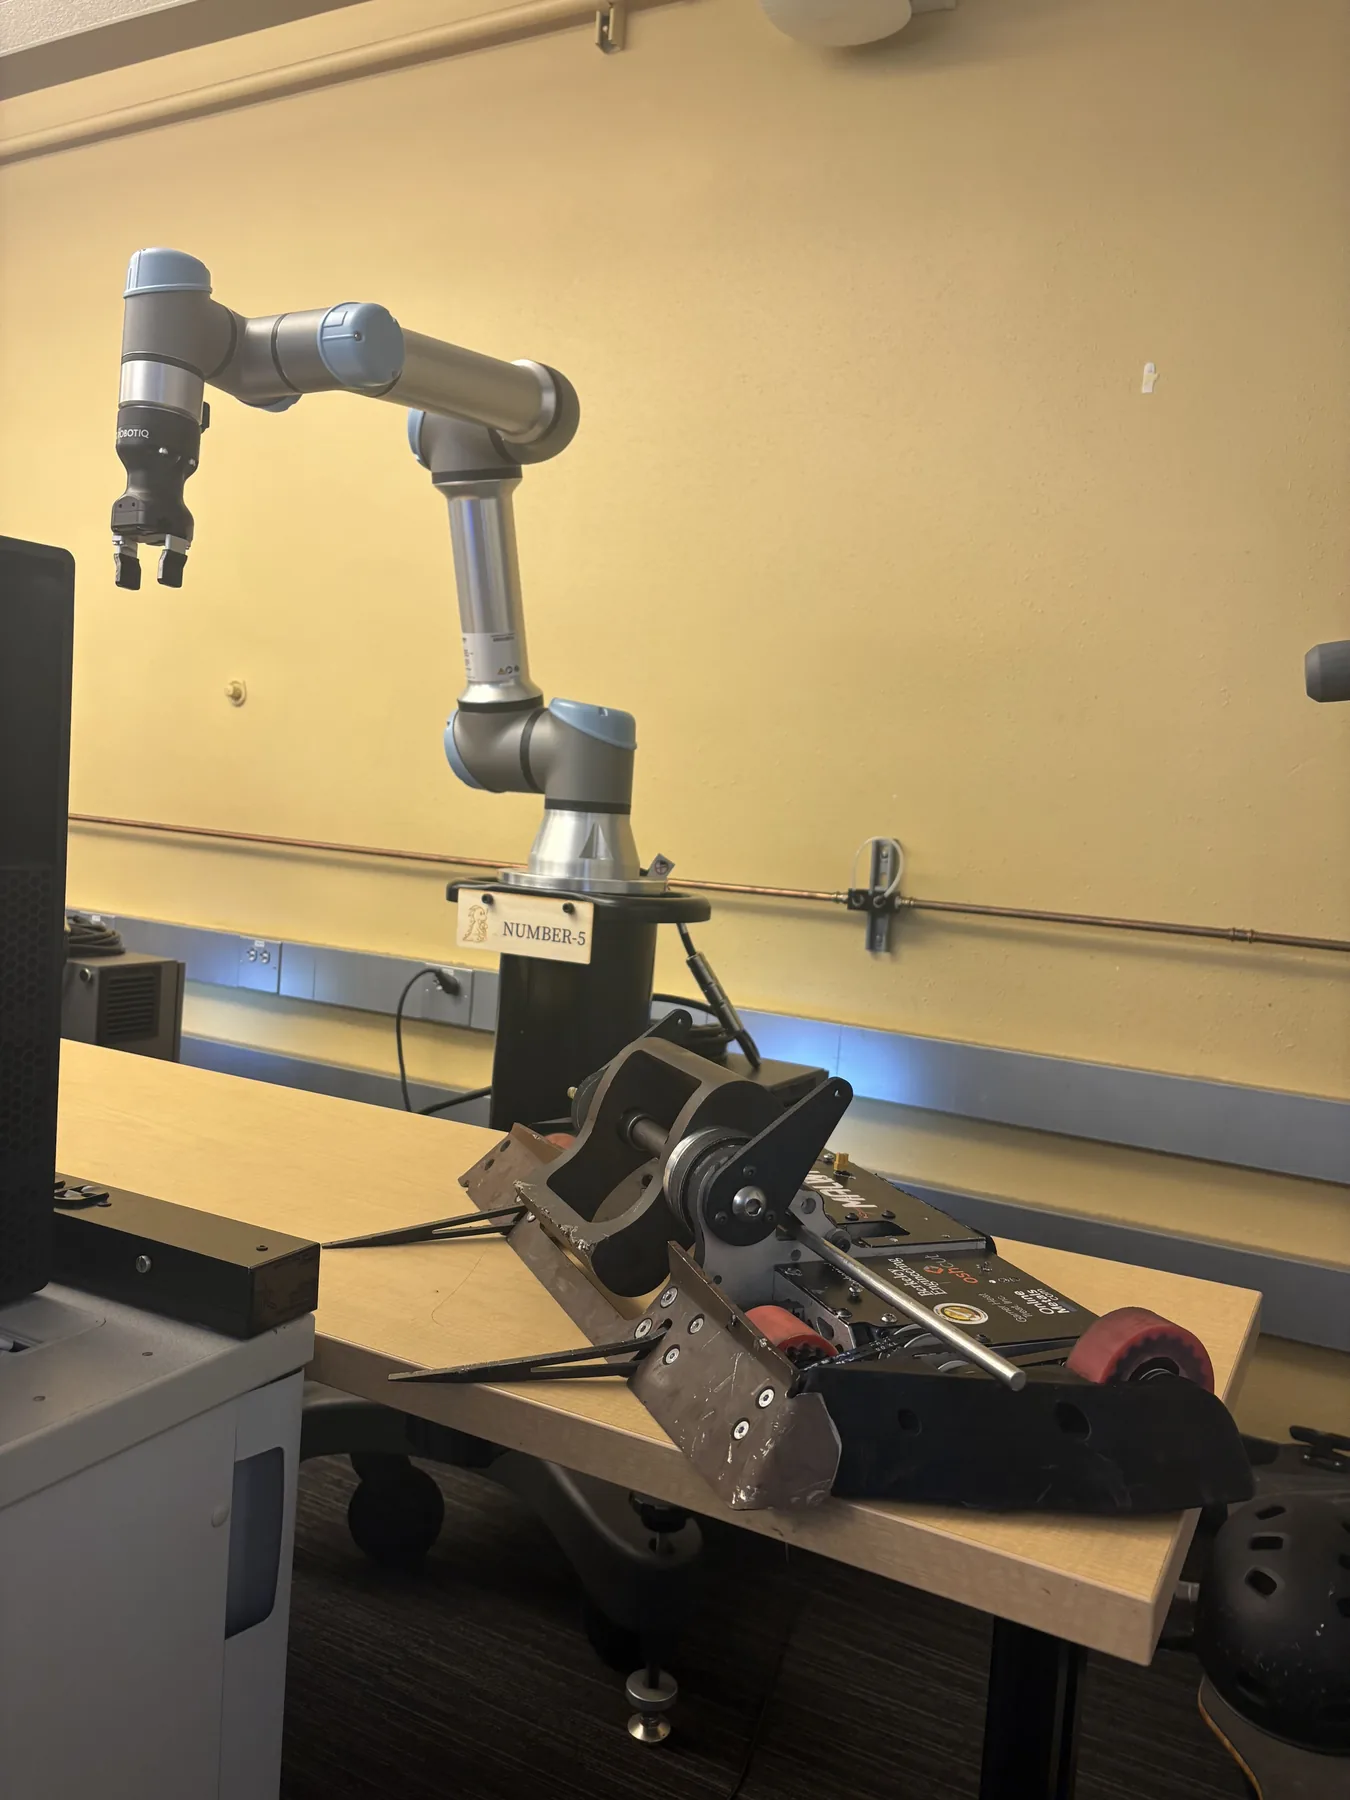
ROBOTICS · HARDWARE
A look at the hardware, mechanisms, and integration work behind getting a robot moving reliably.
OPEN PROJECT ↗UC BERKELEY · IOT
An embedded monitoring project combining sensors, actuators, data, and a real-world application.
OPEN PROJECT ↗FRESHMAN DESIGN
A mass-manufacturable part designed around CAD, scalability, efficiency, and practical manufacturing constraints.
OPEN PROJECT ↗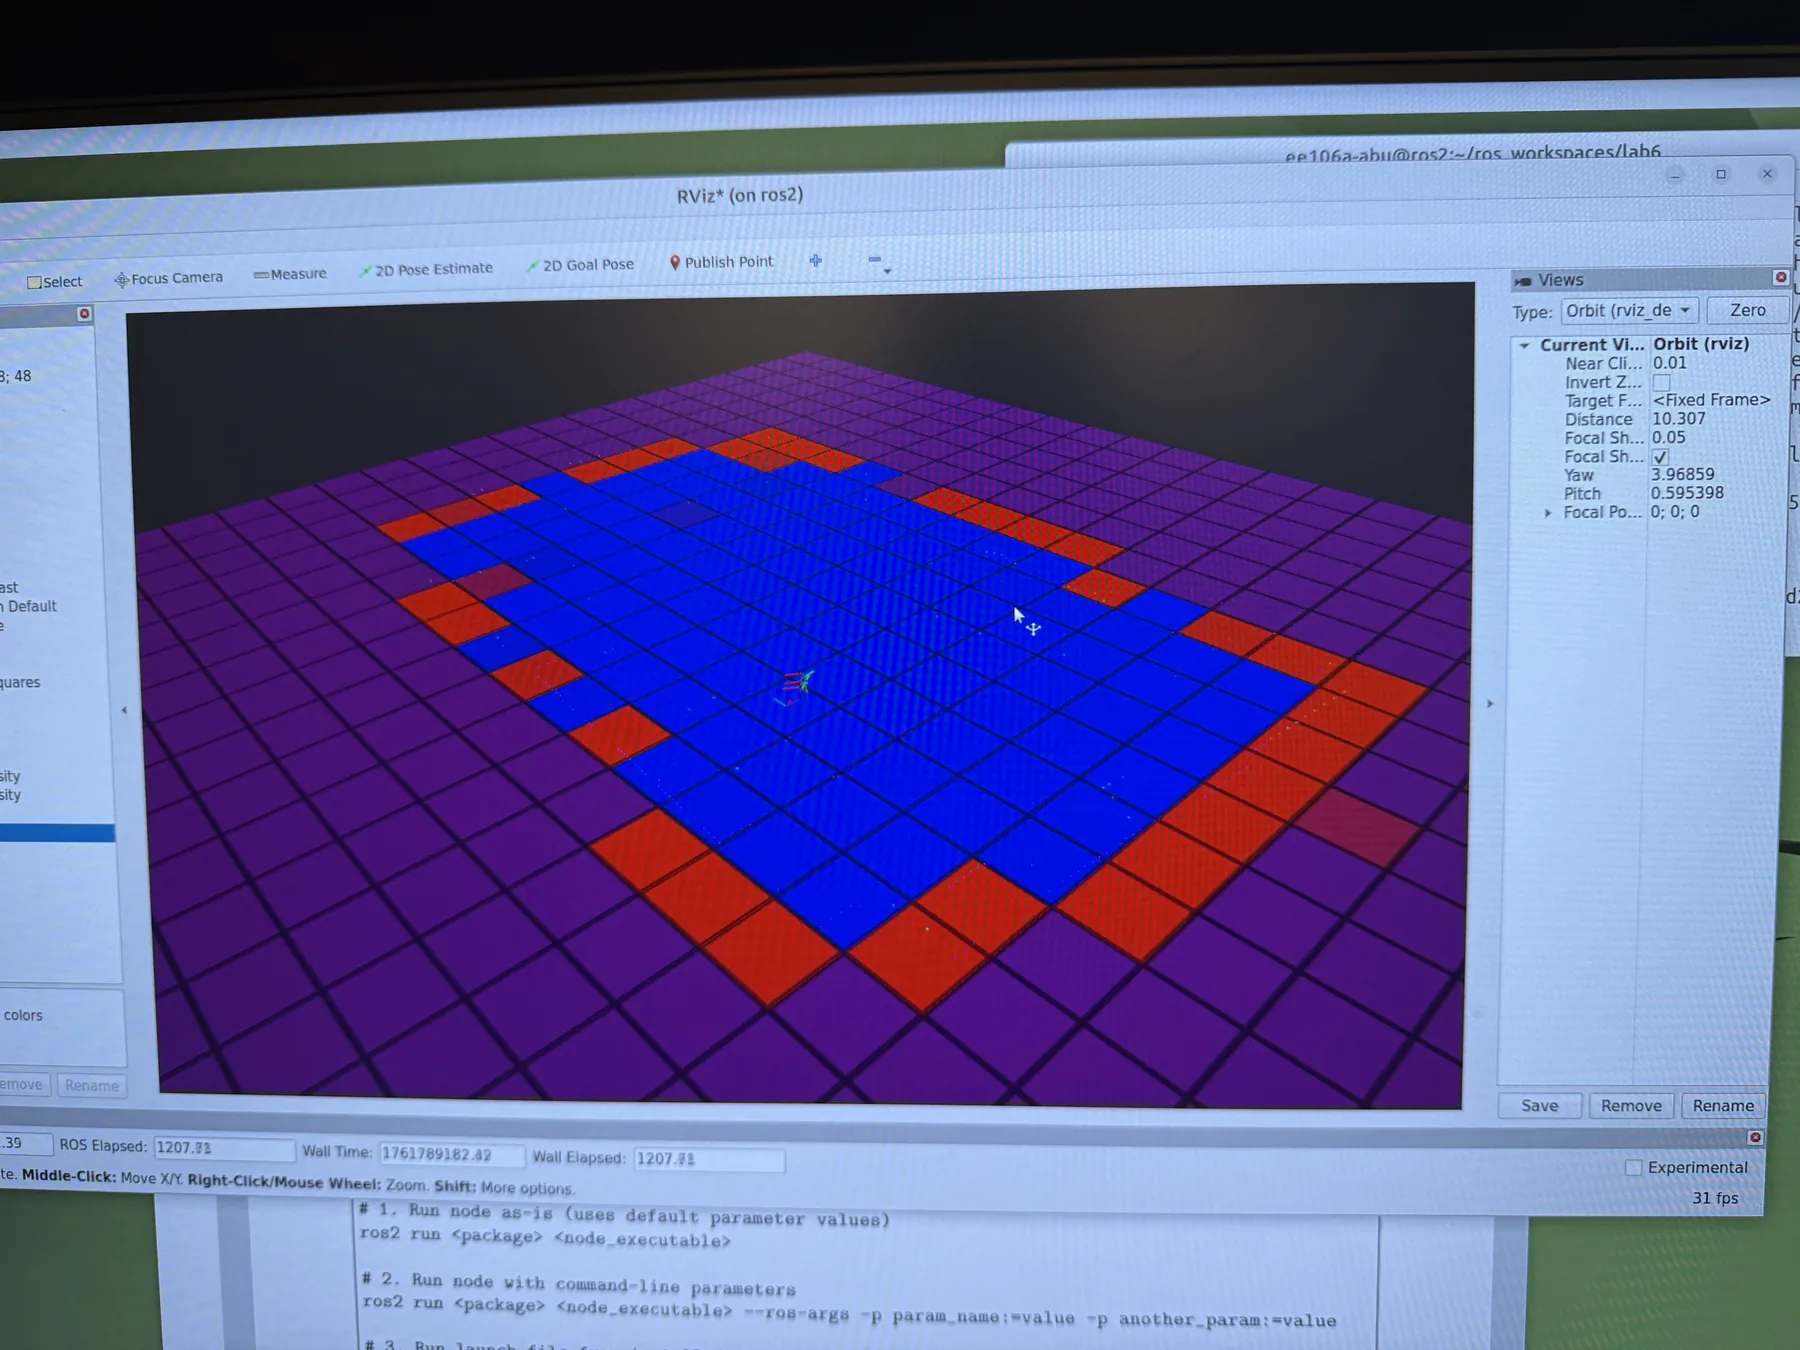
PROGRAMMING · DATA
Jupyter Hub, Python, statistical methods, one-hot encoding, and data analysis.
OPEN PROJECT ↗PRODUCT DEVELOPMENT
A connected helmet concept combining GPS, Bluetooth, sensors, audio, AI, product research, and team coordination.
OPEN PROJECT ↗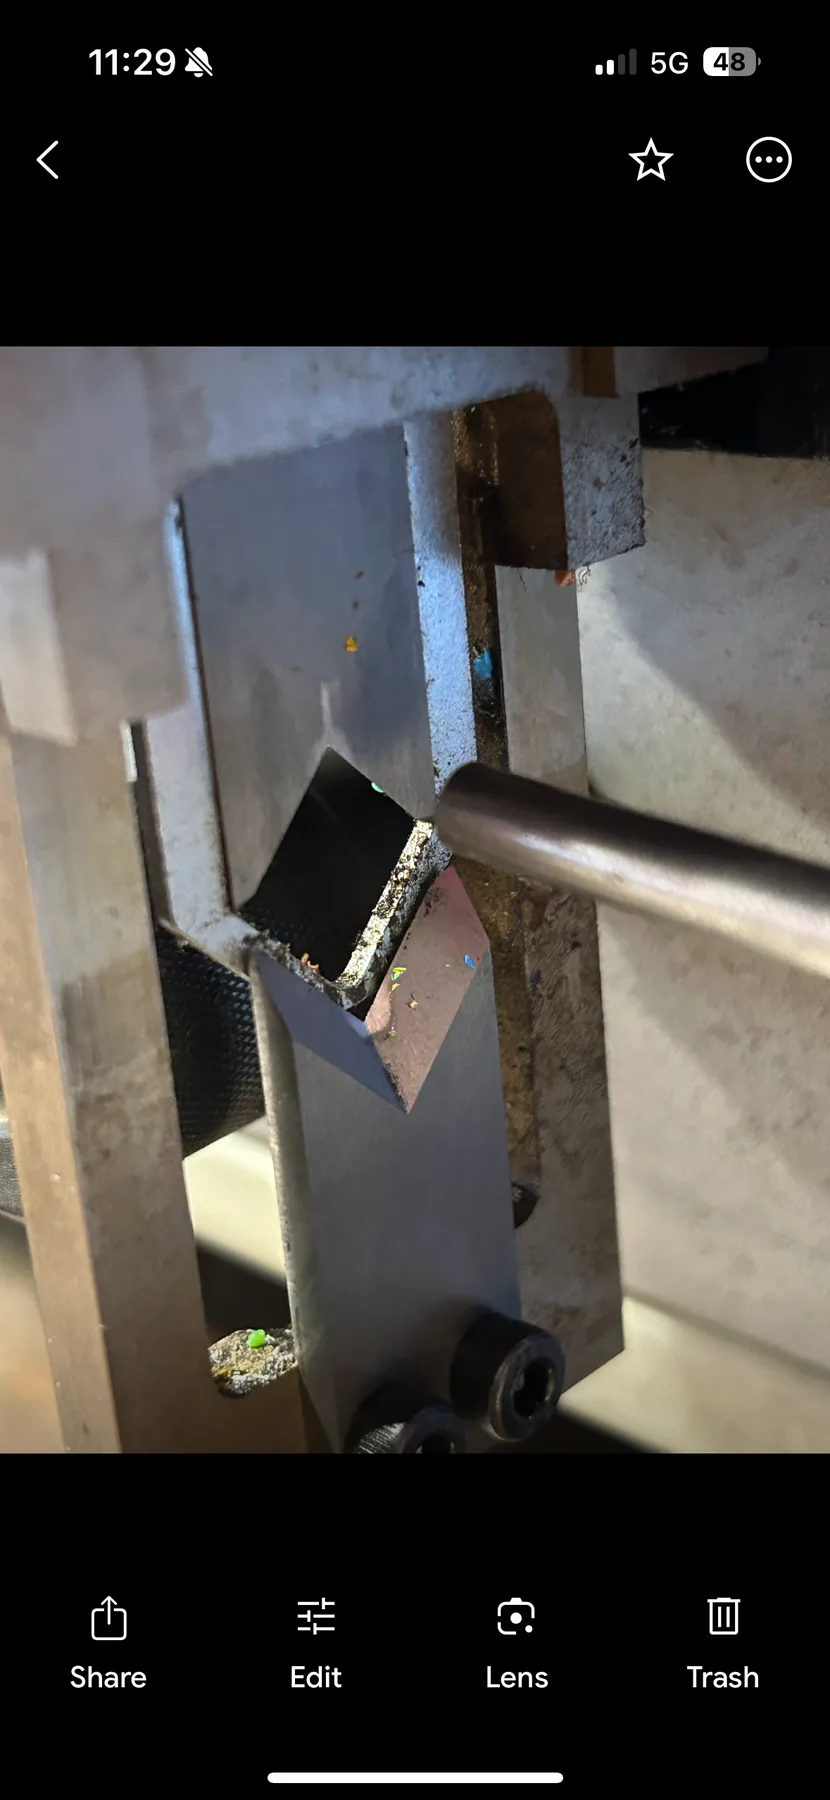
MANUFACTURING · PRODUCT DESIGN
A modular raceway combining pneumatic lines and electrical wiring, designed around safety, manufacturability, installation, and cost.
OPEN PROJECT ↗02 · PLACES WHERE THE MACHINE HAD TO WORK
The experience section is organized around environments, not isolated bullet points: companies, shops, teams, and the systems that came out of them.

End-to-end integration and deployment of a growing robotics fleet for continuous research data collection — hardware, software configuration, networking, validation, technicians, and recovery.
A 120+ member organization where I moved between robot design, manufacturing, shop operations, competition logistics, mentorship, and technical program management.
Prototype-to-production engineering during an alpha-to-beta transition: fixtures, production flow, tooling, parts, takt time, and documentation.
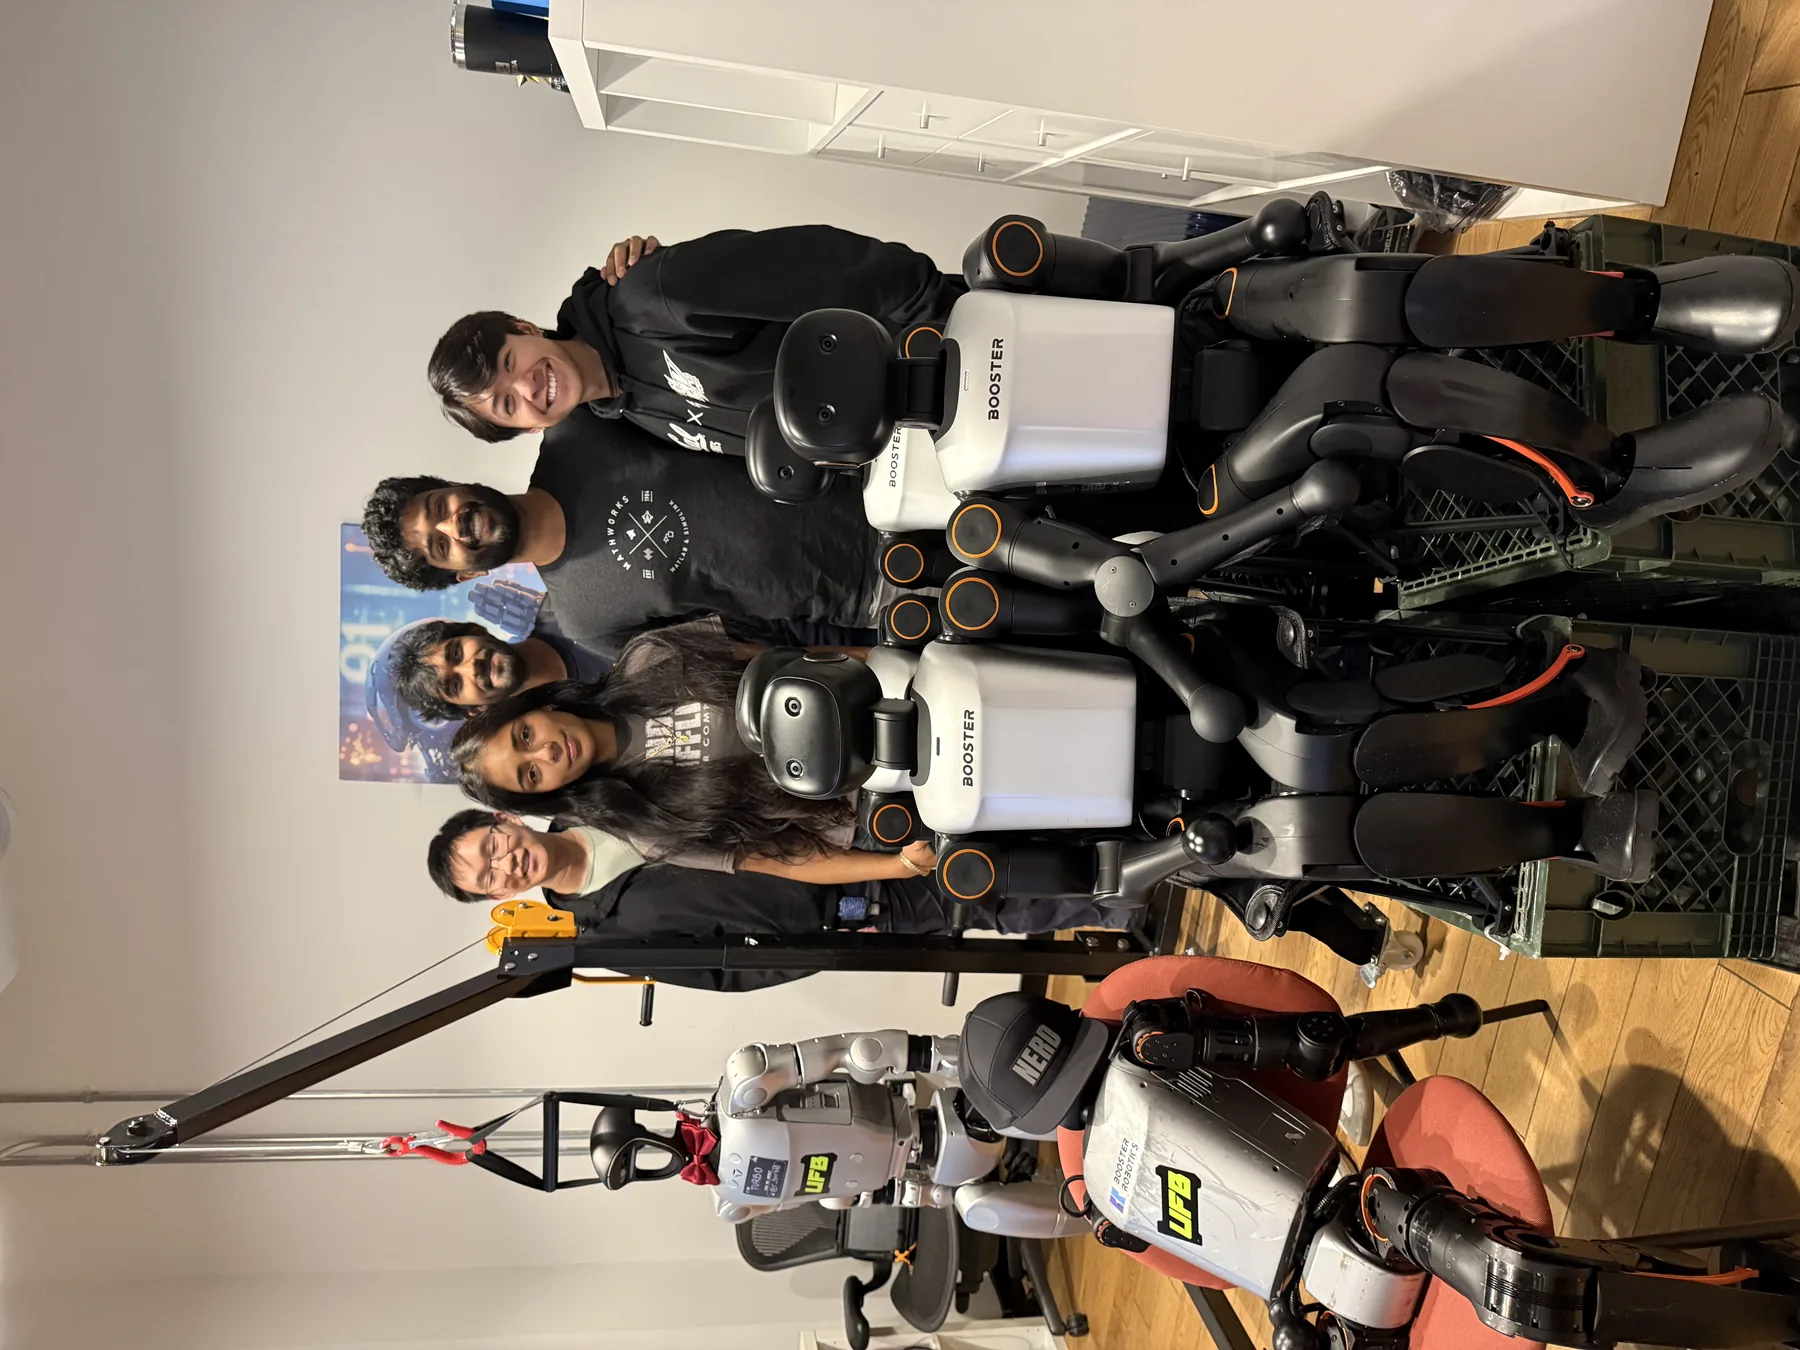
Unitree and Booster humanoid integration where bring-up, motion, debugging, recovery, and live-event execution happen at the same time.
High-altitude airborne sensor systems, PCB assembly, fabrication infrastructure, and production scaling.
Rapid robot prototyping where mechanical design, electronics, soldering, and debugging all had to happen at once.
Manufacturing engineering shaped by real installation, electrical, pneumatic, safety, cost, and production constraints.
03 · HOW I BUILD
My useful range is not a list of software. It is the ability to move from requirement → part → robot → failure → fix → repeatable system.
SolidWorks · Fusion 360 · Onshape · Inventor · FEA · GD&T · mechanism design · DFM/DFA
CNC milling · turning · 3D printing · sheet metal · welding · soldering · reflow · fabrication
ROS 2 · hardware bring-up · sensors · networking · firmware integration · motion · manipulation
Debugging · validation · field fixes · deployment · fleet operations · technician training · documentation
04 · OUTSIDE THE SHOP
Cars. Motorcycles. Machining. Photography. Music. I like machines that are old enough to require a little detective work.
Six-plus years around machining, a Kawasaki Ninja 300, a C4 Corvette, a Jeep restoration, and a restored lathe are a pretty good explanation for why I prefer making things to just talking about them.
05 · MY PAST
Berkeley was more than a degree: robotics, teaching, transportation, rowing, outreach, and the side quests that shaped how I work. It is part of the story, not the identity I am trying to hold onto forever.
120+ members · robot R&D · shop operations · mentorship · competition logistics
Driver · team lead · integration · live competitions
Student-run Insider's Guide to Berkeley Engineering DeCal
Programs and engineering community leadership
Transportation planning, design competitions, AutoCAD, cost estimates, and regulations
Lightweight team rower / coxswain
Graphic design
Networking guest / robotics demonstration expert
Event volunteer
Hosted an engineering tour for Australian students
06 · PUBLIC FOOTPRINT
Interviews, creator videos, live fights, photographs, press, Berkeley records, and the competition trail.